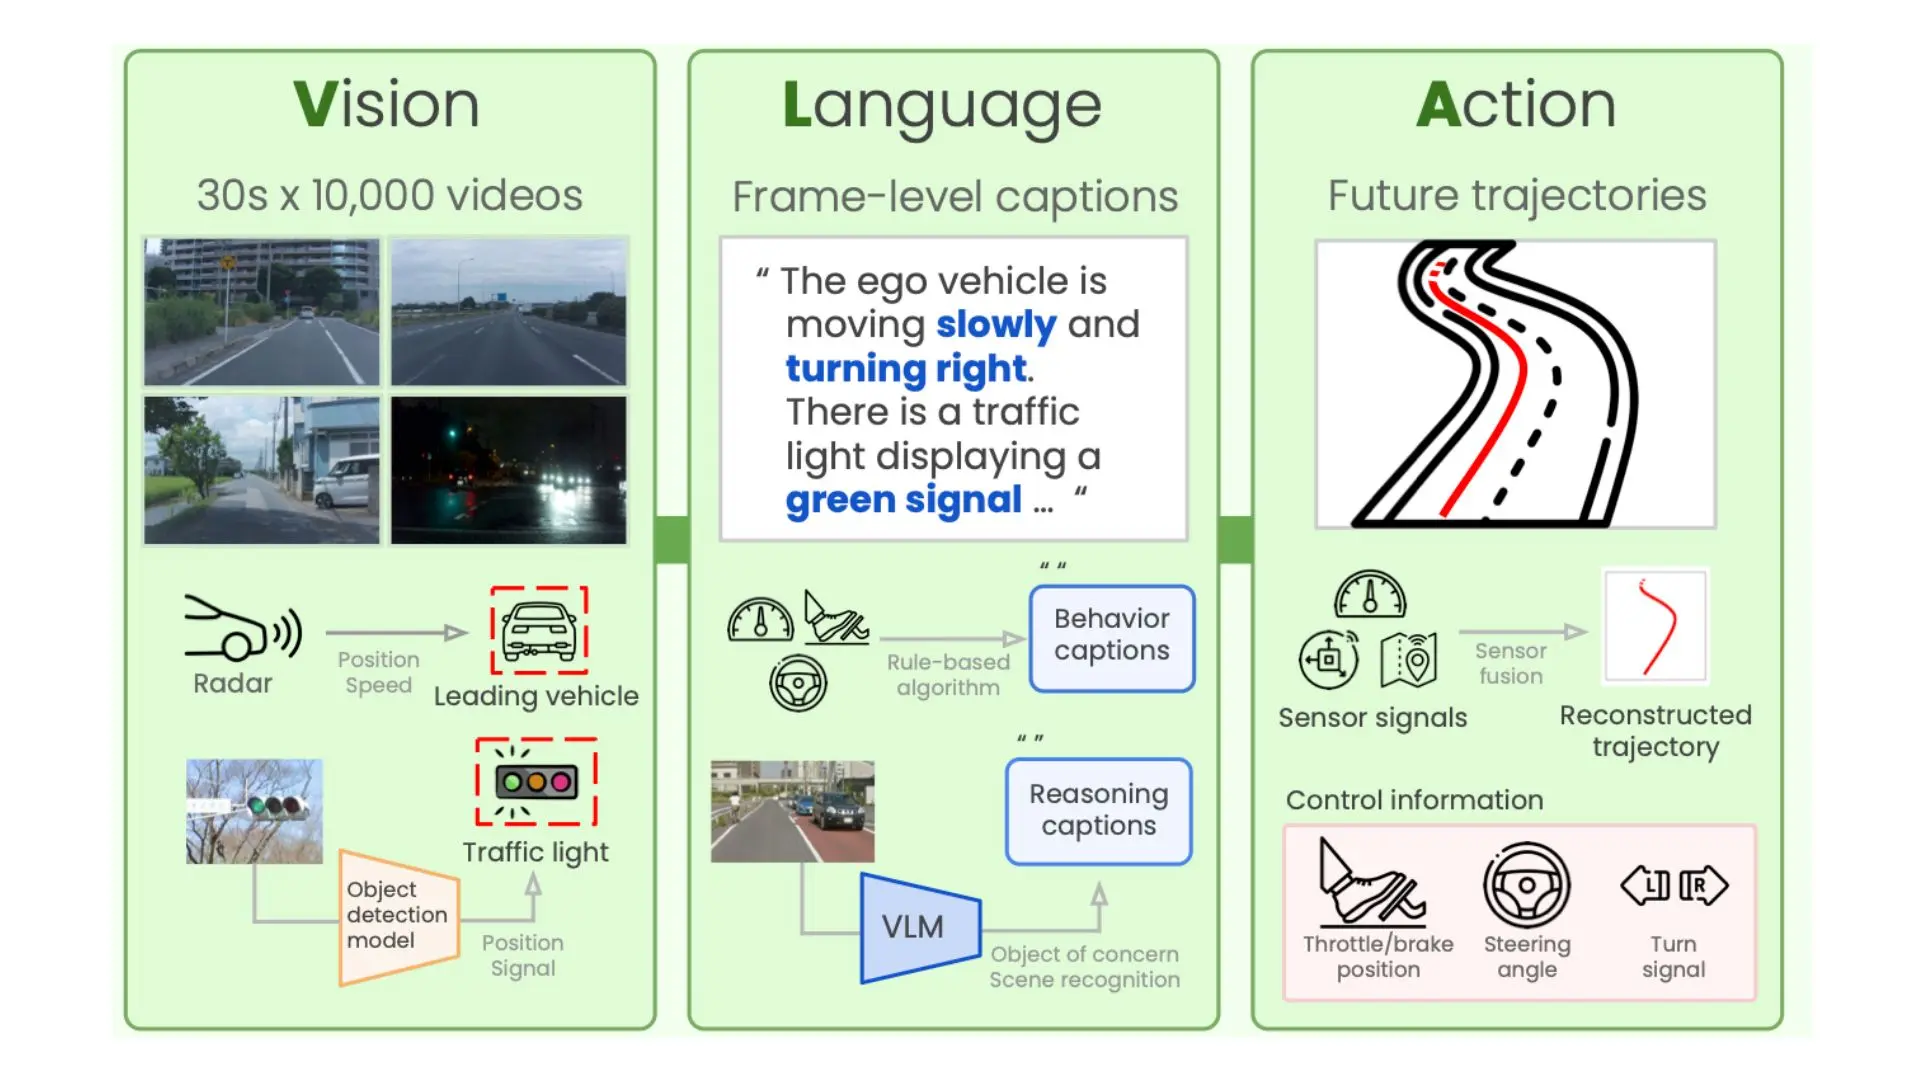
Classical robotic systems are built as pipelines. A perception module estimates the state of the environment. A planner reasons over that state and produces a …
robotics
vla
AI
category · 5 posts
Classical robotic systems are built as pipelines. A perception module estimates the state of the environment. A planner reasons over that state and produces a …
ROS 1 reached end of life in May 2025. Its final release, Noetic Ninjemys, no longer receives patches or updates. For new projects, the answer is ROS 2. For …
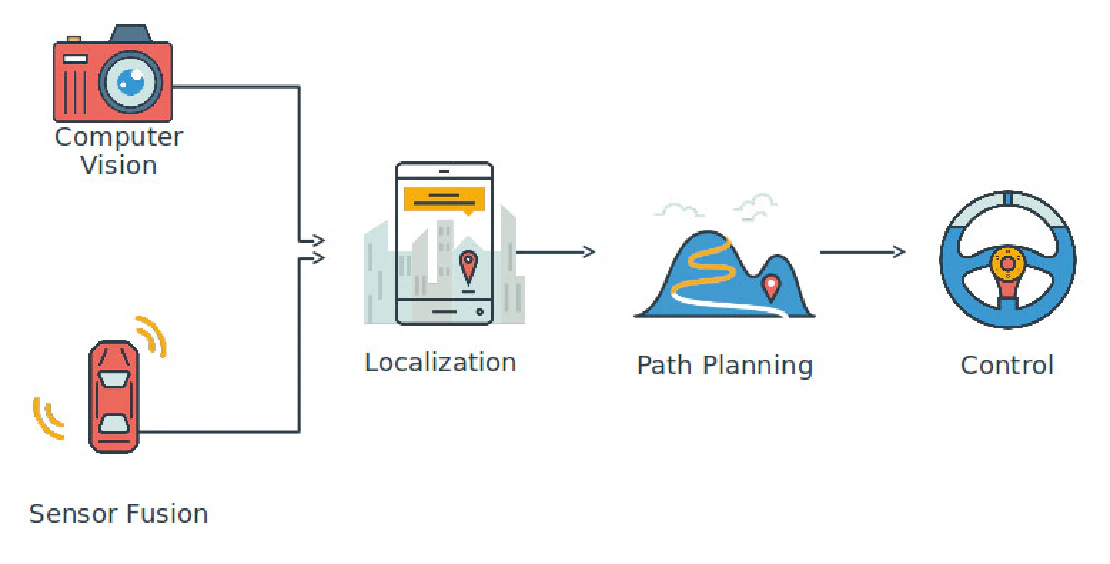
The central question in autonomous vehicle perception is how much of the sensing work to assign to cameras and learned models, and how much to delegate to …
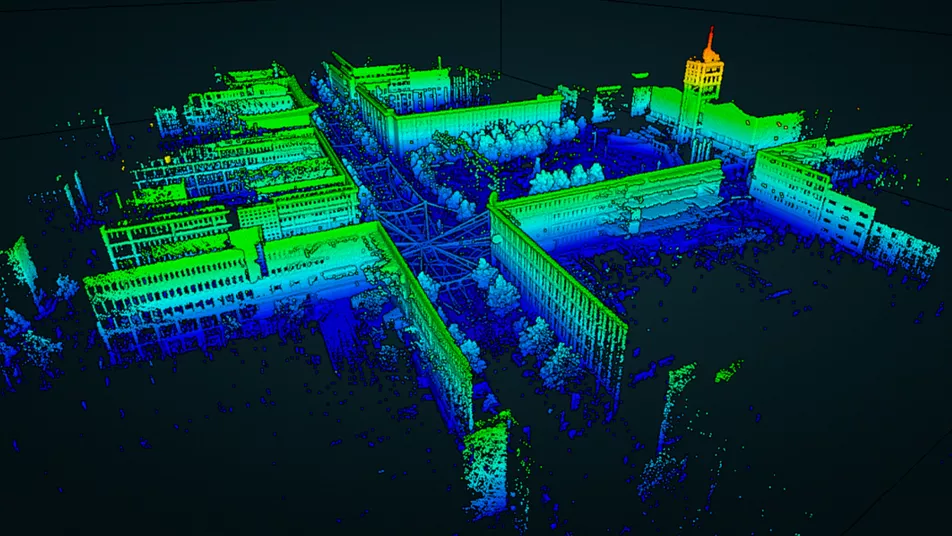
A mobile robot navigating an unknown environment faces two problems that are coupled in a way that makes each one unsolvable without the other. To localize …
Last year I missed ROSCon India because of exams. This year I finally attended ROSConIN'24 at IISc Bangalore, and it ended up being one of the most useful …